Robotics Lab @ Brandeis
sites.google.com
Our new web site for the Robotics Lab. Finally after 5 years I found the time and the help to build a half decent web site
Our new web site for the Robotics Lab. Finally after 5 years I found the time and the help to build a half decent web site
ROS tool to locate the source file for ROS packages. This is a little esoteric unless you are doing ROS development - like I do. But here it is for you ROS nerds.
Good luck to the world with another search engine. Yes google is evil and I wish there was competition. But good luck! "You.com is an ad-free, private search engine that you control. Customize search results with 150 apps alongside web results. Access a zero-trace private mode."
The Robotics Knowledgebase exists to advance knowledge in the robotics discipline.
visualize URDF/XACRO file, URDF Viewer works on Windows/MacOS/Linux - GitHub - openrr/urdf-viz: visualize URDF/XACRO file, URDF Viewer works on Windows/MacOS/Linux
The Yale OpenHand Project is a movement to advance the design and use of robotic hands designed and built through rapid-prototyping techniques in order to encourage more variation and innovation in mechanical hardware.

Freedom Robotics creates powerful control and monitoring software to enable the next generation of robotics companies to build, operate, and scale robots and robotic fleets.

Mecanum wheel Lidar High-precision camera myAGV is jointly developed by Elephant Robot and Huaway. The manipulator uses mycobot and loads camera Eye-in-Hand design. myAGV adopts Mecanum wheel + lidar + high-precision camera. Control mode: autonomous navigation, handle control, keyboard control, etc.
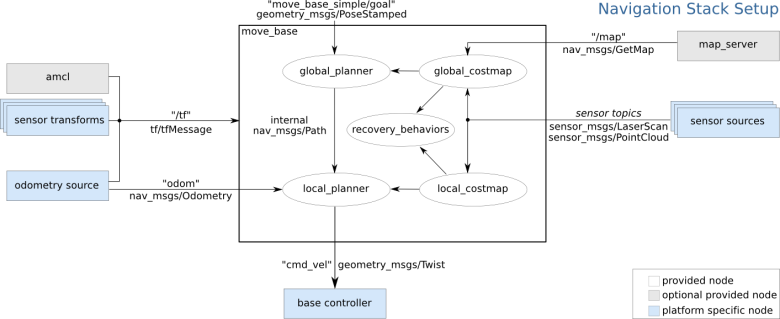
Good information about setting up and conviguring navigation
If you're using ROS on a Raspberry Pi board, check out those useful tips for making more robust, high-performance, and scalable robotics projects!
ROS use OpenCV for camera calibration but the format that it stores the data is different than OpenCV. Also, you need to know where to place the camera calibration files so ROS can find it and publish it. 1.First, you need to install usb cam package from ROS and uvcdynctrl to disable autofocus: sudo apt-get install ros-kinetic-usb-cam uvcdynctrl 2.Open … Calibrating a Monocular Camera with ROS Read More »
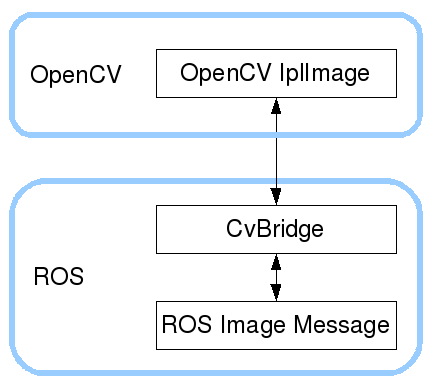
Standard way of pulling images off the camea and into opencv for ROS